Research / Experiment notebook
A body.
A task.
A world.
Evolved walking studies, current maze-navigation experiments, and questions about environmental motility.
01 / Walking studies · June 2026
Evolving a walk.
libPByte / MuJoCo MJX and JAX on one GPU
Can evolution find a way of walking for a body it did not design?
In these experiments, simulated creatures came to walk through selection rather than hand animation. Each run began with a fixed jointed body: a quadruped, a six- or eight-legged radial walker, a two-legged body, or a fifteen-part humanoid figure. Populations of controllers were tried in a physics simulation. Those that carried the body farthest while keeping it up supplied the next generation.
Each clip is a rendering of a trajectory recorded from MuJoCo, not a live simulation in your browser. Body geometry and part colors follow the original replay viewers; the camera, lighting, labels, and path line are presentation choices.
What evolved
Bodies were authored and remained fixed within each run; evolution acted on their controllers. A rhythm drives each joint group. In the first studies, ten inherited numbers set its frequency and, for hips, knees, and side-to-side hip joints, the amplitude, center angle, and timing. Radial walkers also inherit a timing for each leg. Later two-legged bodies added a small recurrent neural network that senses lean, height, and foot contact, and corrects the rhythm as the body moves.
What the evaluator rewarded
The first score was forward distance in a five- or six-second trial, reduced when the torso sank or drifted sideways. Two-legged bodies exposed weaknesses in that score, so later runs gave credit only while the body stayed up and upright with a foot on the ground. They also rewarded alternating feet, bent knees, and arms swinging against the legs.
Read the method
Each body was described as a genome in the libPByte TypeScript library. A Python translation of that description built a model for MuJoCo, a physics engine for jointed bodies. With MuJoCo MJX and JAX, an entire population was simulated in parallel on one NVIDIA A100 GPU on SMU’s SuperPOD. The documented quadruped run took about 80 seconds; the hexapod run took about 100 seconds for 30 generations.
The quadruped, radial walkers, and biped variants used an elitist genetic algorithm: each generation retained its highest-scoring controllers and filled the remaining places with randomly mutated copies of them. Later humanoid runs used CMA-ES, an evolution strategy that adapts the shape of its search, while keeping the best controller found so far in each generation.
Walking was not achieved in libPByte’s browser physics engine, Rapier. Its joint motors drift apart when hip, knee, and ankle are chained in one leg. A quadruped evolved there for distance scrambled forward and fell; versions with posture feedback stayed upright without sustaining a walk. MuJoCo’s reduced-coordinate solver holds the chain together. The browser therefore replays recorded MuJoCo trajectories rather than simulating the walkers live.
Notebook / June 21–23, 2026
What emerged.
1.74 → 5.26 m hexapod forward distance, generation 0 to generation 29, in a five-second trial
Each body plan found a way to move forward while staying up. The quadruped walked straight and level. The six-legged walker more than tripled its distance in 30 generations, and an eight-legged walker’s longest recorded replay reached 6.49 m. These are different bodies and settings, not a controlled comparison of leg number.
Two-legged bodies were harder. Sensory feedback helped where there was a fall to catch: in the development log, the armless biped improved from 0.84 m with 90% of the trial upright to 1.13 m with 97%, while the already stable hexapod was unchanged. The humanoid figure began by falling and eventually walked upright with alternating steps, but slowly, around a tenth of a meter per second. Across roughly a dozen further runs, the method kept finding slow, stable gaits rather than a fast dynamic walk.
Evolution also found a loophole. When staying up was judged by pelvis height alone, a biped with a passive tail scored best (2.88 m) by reclining about 73° onto its tail and scooting as a tripod. Requiring an upright body removed that strategy; re-evolved, the same body leaned about 20° and traveled 1.20 m.
What these studies support
Evolutionary search found working gaits for authored bodies inside MuJoCo. The studies do not show evolved anatomy, real-world locomotion, or transfer to other simulators. Each result depends on the chosen body, the seeded starting rhythm, and scoring rules that were revised between runs.
Most entries are single runs with one seed and no uncertainty estimates. Fitness definitions differ between studies, and distances are simulated meters within each study’s settings. No cross-study performance ranking is asserted here.
02 / Current experiment
Finding a way.
protoAdapt / Maze navigation
Can an inherited controller find a goal in an unfamiliar maze?
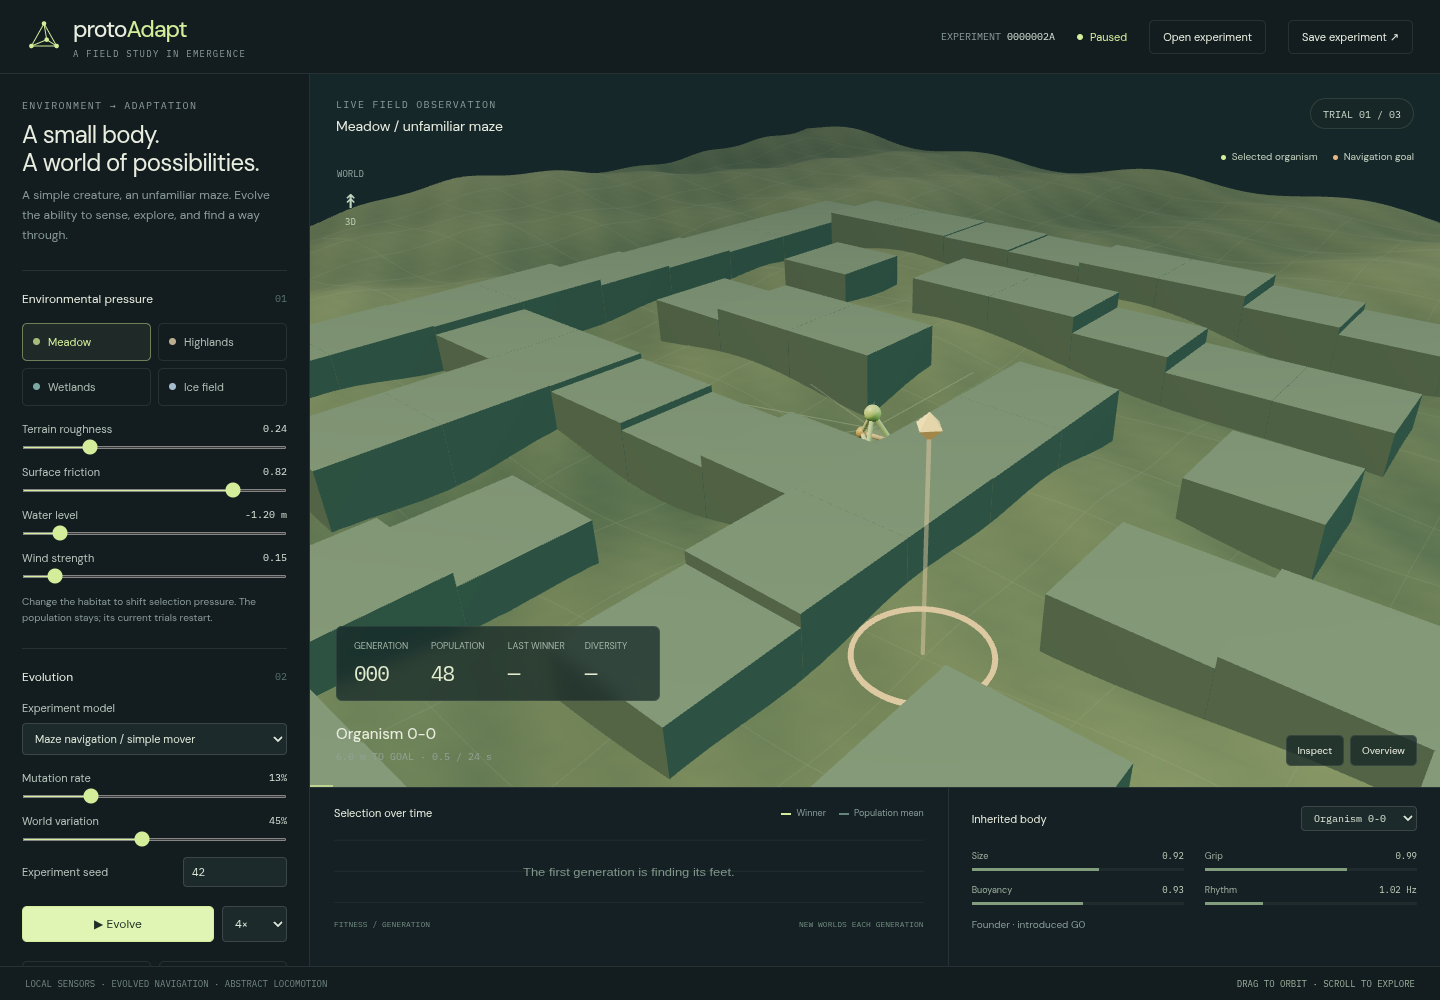
A small creature senses nearby obstacles, the goal’s direction, and local conditions. Across generations, selection acts on how well its inherited controller navigates. Body parameters such as size, mass, grip, and buoyancy vary too.
What the creature knows
Five short obstacle rays, goal bearing and straight-line distance, movement, and environmental signals feed a reactive neural controller. It receives no maze map or prewritten route. Its weights remain fixed during its lifetime; inheritance changes them across generations.
What the evaluator knows
The evaluator can use shortest-path distance to measure progress around walls, even when a useful move points away from the goal. That information is kept out of the controller. Scores also account for arrival, exploration, effort, and collisions.
Read the experimental setup
Each generation evaluates 48 candidates in three shared randomized worlds for 24 simulated seconds per trial. The selection score is 75% mean trial score plus 25% worst trial score. Tournament selection, crossover, Gaussian mutation, retained elites, and random immigrants produce the next population; elites are tested again in the new worlds.
The 220-value genome includes body and rhythm parameters and an 18-input, 8-hidden-unit, 6-output neural controller. Navigation uses the first two outputs for abstract propulsion and steering. This movement model includes simplified traction, inertia, terrain, wind, and water effects. The creature does not walk; this experiment concerns navigation. The evolved walking studies above use separate jointed bodies in MuJoCo.
There is no learned memory or lifetime weight update. The experiment is neuroevolution: evolutionary search over neural controllers. The environment affects both immediate behavior and which genomes reproduce.
Notebook / September 24, 2026
An initial comparison.
9 of 12 test goals reached by each evolved controller
Two runs began with the same seed-42 population and used equal budgets: 30 generations, 48 candidates, three training worlds per generation, and 24 seconds per trial. One population evolved in meadow conditions, the other in wetlands. Their final-generation winners were evaluated on the same three unseen maze seeds in each of four habitats.
| Test habitat | Meadow-trained score | Goals | Wetland-trained score | Goals | Random founder mean score |
|---|---|---|---|---|---|
| Meadow | 65.71 | 3/3 | 64.60 | 3/3 | 0.36 |
| Highlands | 39.62 | 2/3 | 39.83 | 2/3 | -5.35 |
| Wetlands | 41.26 | 2/3 | 39.56 | 2/3 | 2.24 |
| Ice | 40.46 | 2/3 | 41.30 | 2/3 | -0.49 |
Scores are means of the experiment’s composite reward, not percentages. Each goals entry is out of three trials. The founder baseline averages eight randomly initialized genomes on those same test worlds. The retained reports use zero-based generation 29 for the thirtieth evaluated generation.
What this comparison supports
Both evolved controllers scored above the random-founder baseline in these tests, and both reached 9 of 12 goals. The comparison does not establish that habitat-specific training produces superior specialists. It uses one training seed and a small, fixed test set.
A stronger study will need multiple independent seeds, equal evaluation budgets, fresh test mazes, and uncertainty estimates. Once a test set informs development decisions, it becomes a validation set; final evaluation needs new cases.
03 / Experimental and planned
Movement shaped
by a habitat.
Toward motility and function
An experimental muscle mode already replaces abstract propulsion with a four-node body connected by six contracting springs in open terrain. Its controller changes spring rest lengths; gravity, contact, friction, damping, buoyancy, and wind affect the resulting motion. It may roll, slide, or twitch. Unlike the jointed MuJoCo bodies in the walking studies, this spring body has not yet produced a reliable evolved walk.
The next inquiry is whether changing conditions consistently changes which bodies and movement strategies succeed. Proposed comparisons include grip on ice, effort on slopes, clearance through narrow passages, and movement under different water and drag conditions. Broader body structures, swimming, and richer functions remain research directions.
To attribute an advantage to a trait, we need controlled comparisons: change that trait while holding the rest fixed, repeat the trials, and test the result in new conditions. An appealing movement is a reason to investigate; its functional explanation needs evidence.
How we plan and document a study ↗Continue through the research
Research into practiceResearch notes · September 25, 2026 · Ira Greenberg’s studio